GuidesRobot and arm controlRun two arms
Run two arms on one PC
Plug two arms into one PC, one adapter each, and drive them as one robot or as two independent sessions.
Two arms on one PC need two USB CAN adapters, one per arm. From there you can drive them together, as one robot with one set of joints, or apart, as two sessions that know nothing of each other.
Plug them in
Give each arm its own adapter and power. One arm must be a left arm and the other a right arm: that is how the software tells them apart, and every board carries which side it belongs to. On Windows the second adapter needs its driver too, once on this PC (Give the adapter its driver on Windows).
from makiina.actuator import list_channels

list_channels()          # one entry per adapter, with its serial number
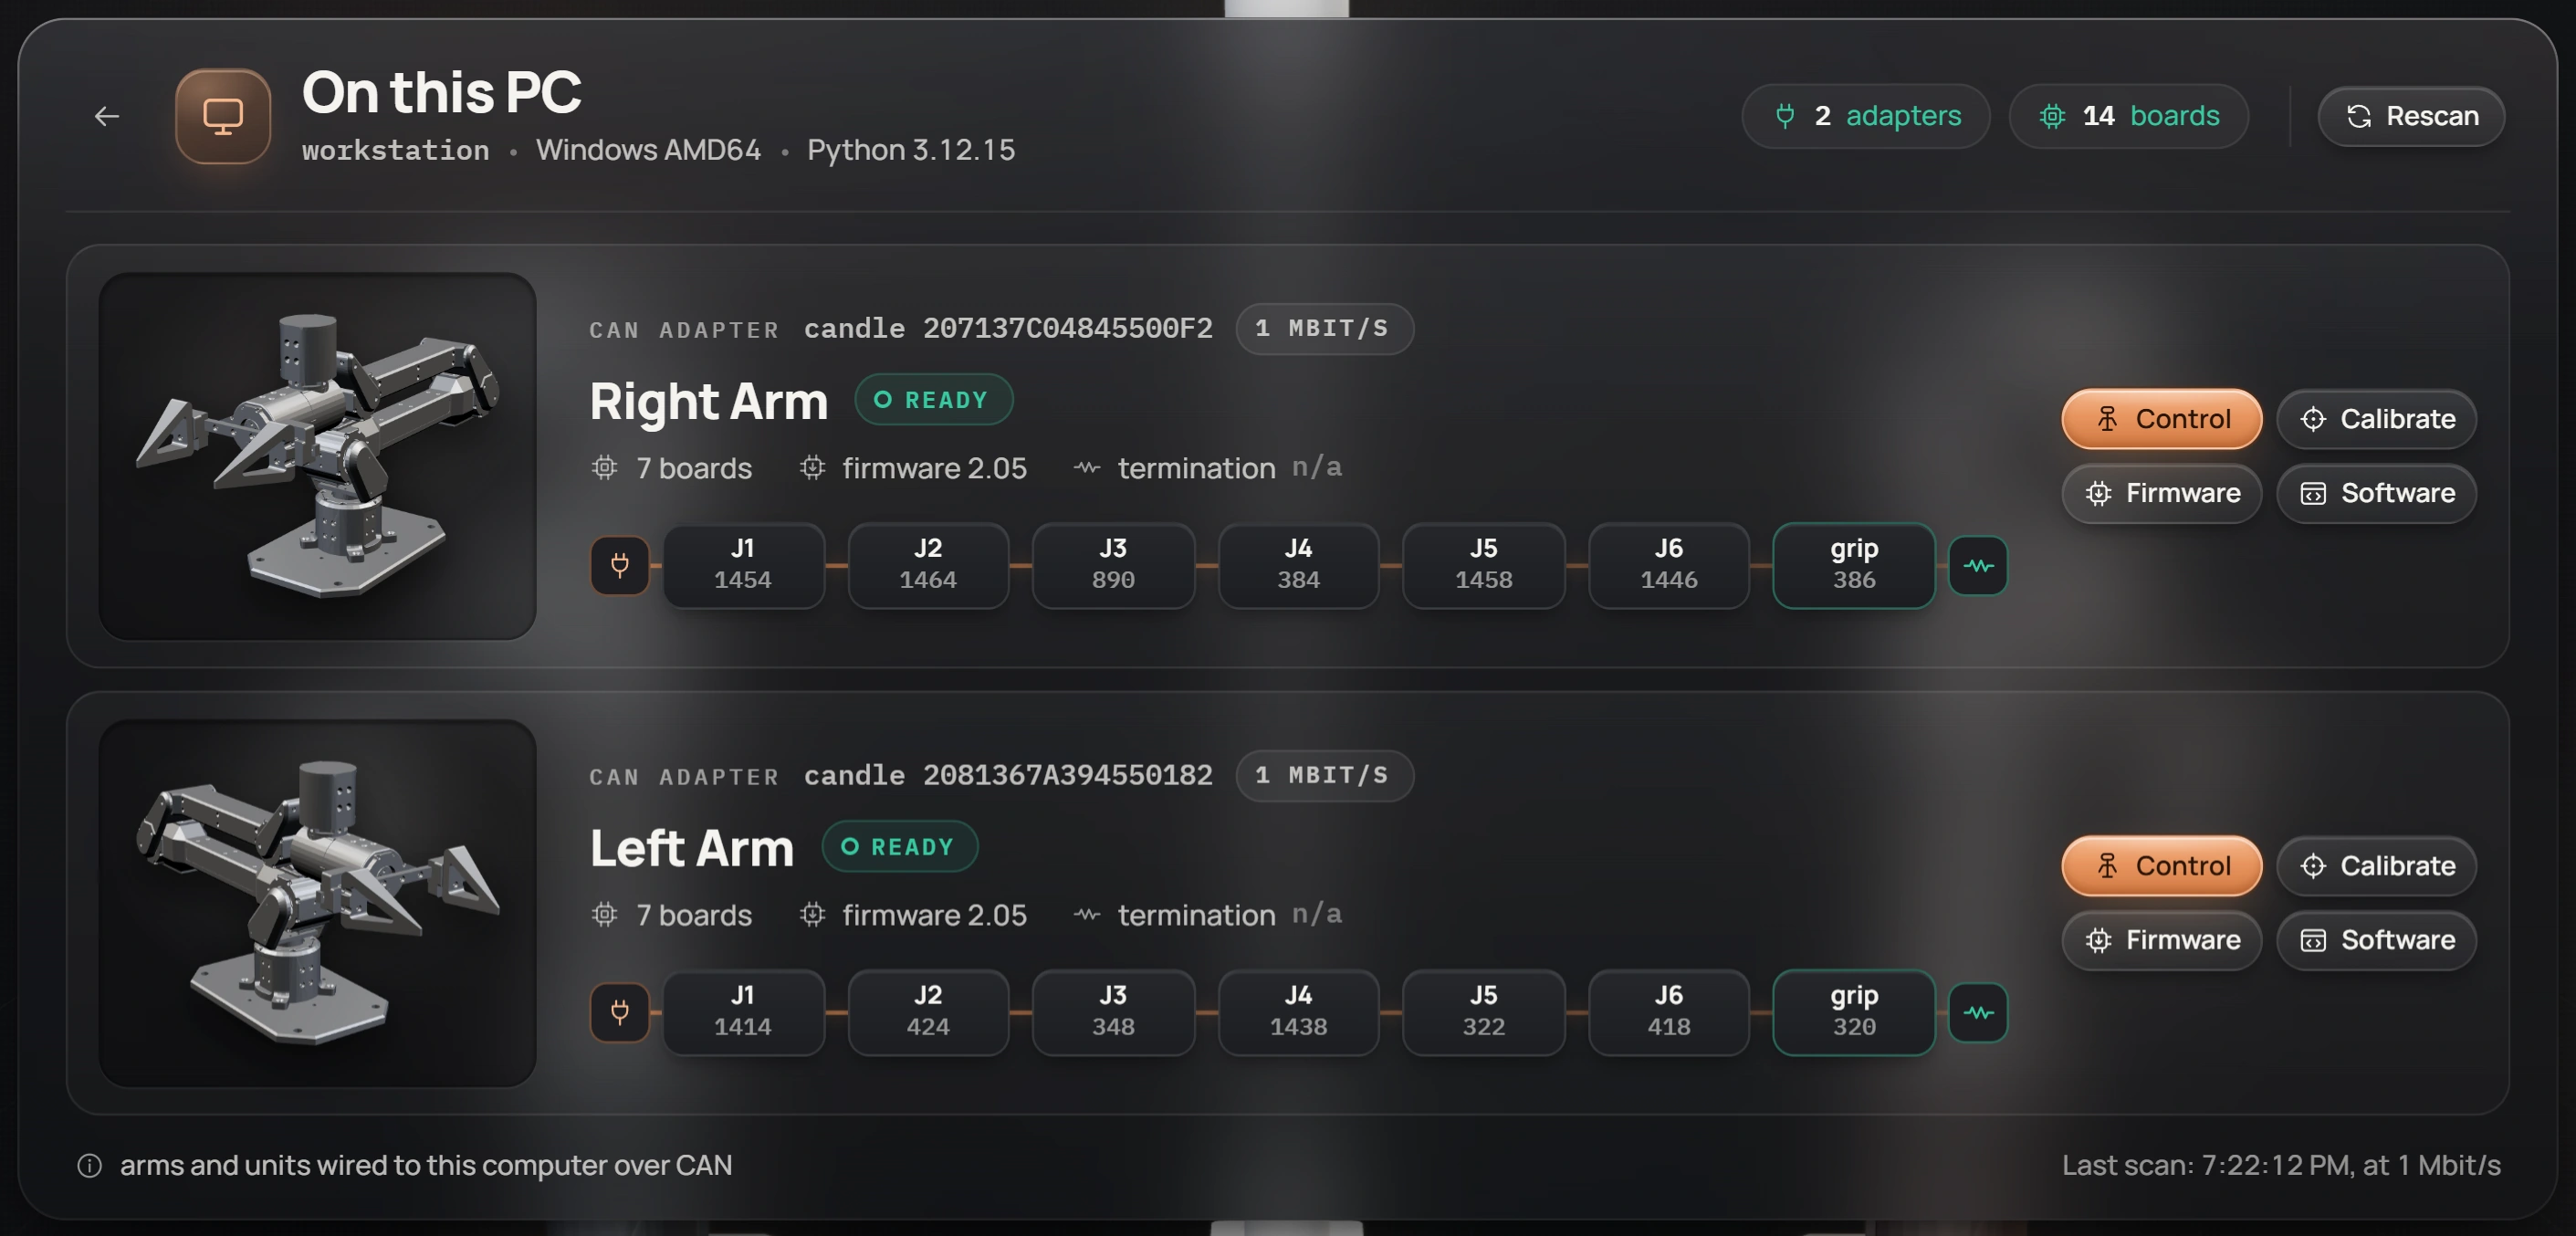
In the console, On this PC shows both arms, each on its adapter, each with its own row.
Drive them as one robot
A session on your PC takes every adapter it finds, so with both arms plugged in you get both in one robot:
from makiina.robot import Robot

robot = Robot.connect_local()
robot.parts                     # ["left_arm", "right_arm"]
robot.sensors.get_joints()      # J01-R to J06-R and J01-L to J06-L
One session means one set of limits, one command loop and one clock for both arms, which is what you want for coordinated moves:
robot.control.set_joints_relative({"J01-R": 0.1, "J01-L": -0.1})The console does the same: Control on either row opens one session with both arms, and the L and R chips next to ARM let you gate one of them while you work with the other. A gated arm holds where it is, but its gripper opens when you move the other gripper's slider (Open and close the grippers).
Drive them as two sessions
To run the arms from two scripts, or to keep a crash in one from touching the other, open one session per adapter. Each session starts its own robot server, so the second one needs its own port and its own log file:
right = Robot.connect_local(adapters=[{"interface": "candle", "channel": "207137C04845500F2:0"}])
left = Robot.connect_local(adapters=[{"interface": "candle", "channel": "2081367A394550182:0"}],
                           port=8771, server_output="left-server.log")

right.control.set_joints_relative({"J01-R": 0.05})
left.sensors.get_joints()
The two sessions have separate limits and separate command loops. They share your PC's settings folder and so its log, logs/<name>-server.log, which the second server would empty as it starts: server_output gives the left arm its own log, left-server.log in the folder you run the script from. The Robot Console cannot drive one arm next to a script on the other: its Control takes every adapter.
Two arms on one bus
Put each arm on its own adapter, as the dual arm system does. Every board stores which arm it belongs to, so a session on one shared bus still tells the left joints from the right ones, but two things work against it:
- Calibrate and Firmware look for one arm per adapter. On a bus that also carries the other arm's boards they find no arm and ask you to pick a bus.
- Each board takes its CAN id from its chip, and each arm was checked on its own bus, so a board of one arm can share its id with a board of the other. Two boards on one id hide each other (Two boards on one id).