ReferenceHardware
Hardware
The numbers and conventions of the MAKIINA arm, actuator, head and robot that matter when you write code.
This page has the facts about the hardware that you need while programming it, with the numbers the robot and the SDK work with.
The arm
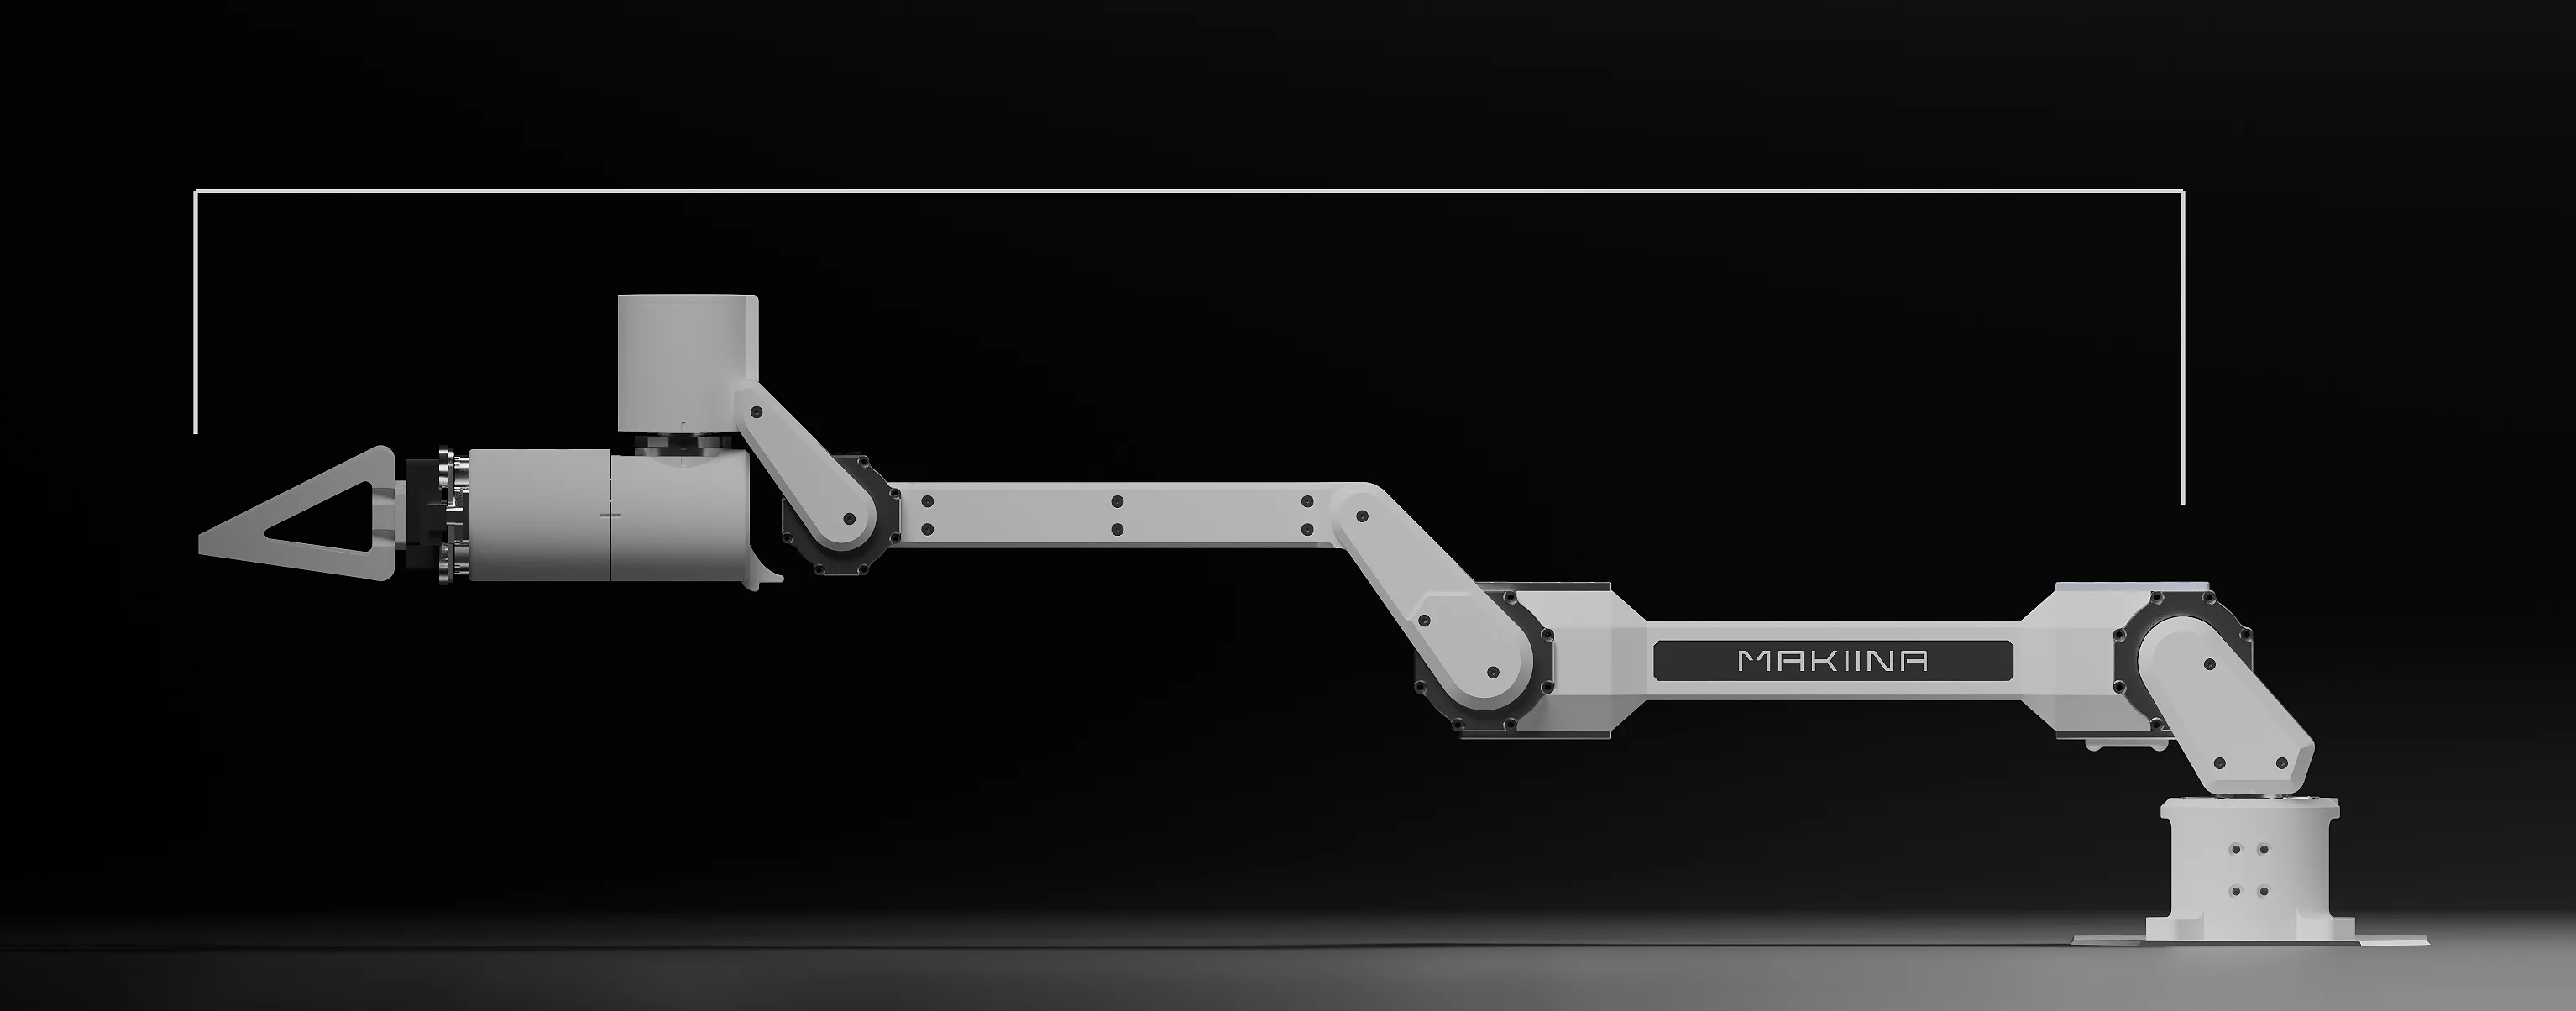
| Degrees of freedom | 6, plus a parallel gripper |
| Reach | 720 mm |
| Weight | 2.4 kg |
| Peak payload | 1.5 kg, measured without the gripper |
| Structure | CNC machined aluminium |
| Actuators | MAKIINA cycloidal, 22 N m peak at the base joints |
| Control | 14 kHz current loop on every drive; position, velocity, current and torque modes |
| Bus | one CAN bus per arm, 1 Mbit/s, one USB CAN adapter per arm |
| Power | 24 V DC from your own supply (not included): 250 W or more for one arm (the product page's 500 W also works), 500 W for the dual arm system; a smaller supply limits the torque |
| Limits at delivery | current limits of 8 A at J1 to J3 and 5 A at J4 to J6, and speed limits, below what the actuators can give; every session starts at them; raise them in Tune the joints |
Joints from the base to the gripper, with the right arm's names (the left arm's end in -L):
| Joint | Name | Moves | Motor size |
|---|---|---|---|
| J1 | J01-R | base yaw | big (medium preset) |
| J2 | J02-R | shoulder | big |
| J3 | J03-R | elbow | big |
| J4 | J04-R | forearm roll | small (small preset) |
| J5 | J05-R | wrist pitch | small |
| J6 | J06-R | wrist roll | small |
| gripper | trigger "right" | the two fingers; positive closes | small |
The big joints, J1 to J3, have a 38:1 cycloidal reducer. The small joints, J4 to J6 and the gripper, have a 39:1 cycloidal reducer. Velocity limits you set with safety.set_max_joint_velocity are in rad/s at the joint; the SDK converts them for each drive.
The zero pose has every joint on its alignment mark: the upper arm lies level, the elbow is fully closed so the forearm lies back over it, and the gripper is open. The 3D twin shows this pose when every joint reads 0. The calibration wizard's first step calls it "an arm stretched straight out": follow the twin (Put the unit at its zero pose). model.named_poses() also holds neutral, a raised ready pose.
The Medium Actuator
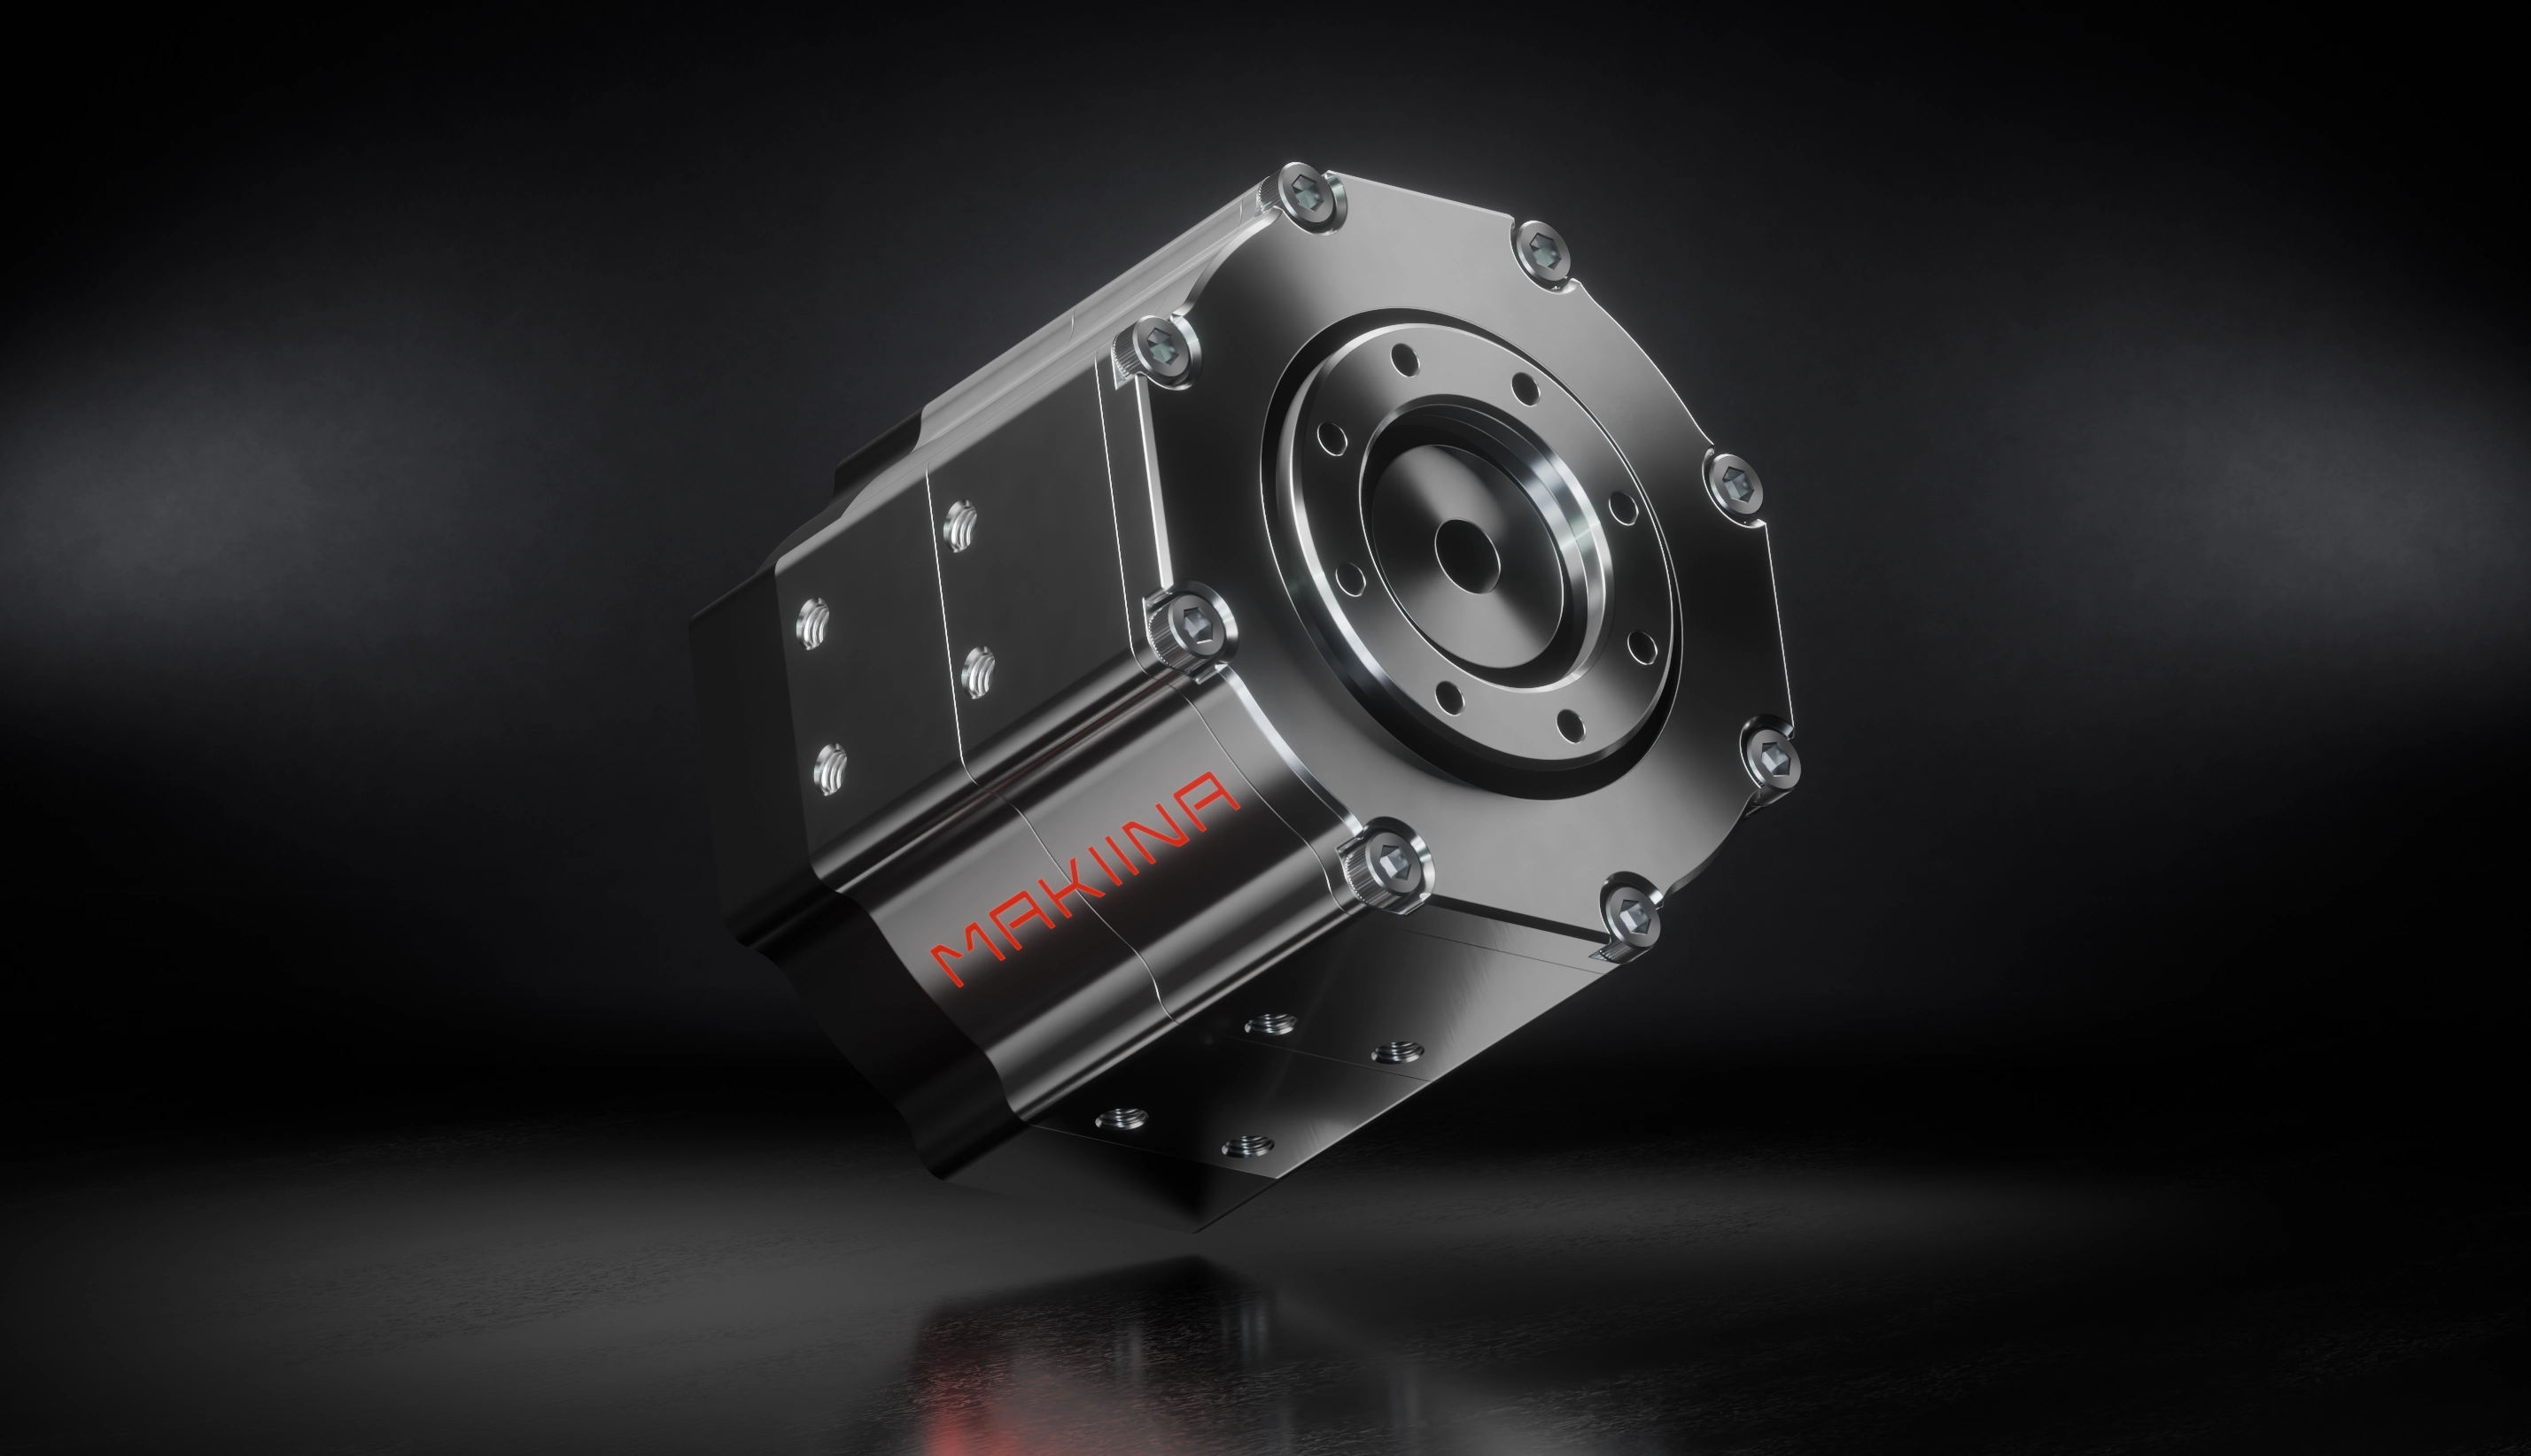
| Size | 50.1 x 50.1 x 47 mm |
| Weight | 240 g |
| Reducer | 38:1 cycloidal |
| Rated torque | 10 N m |
| Peak torque | 22 N m |
| Top output speed | 117 rpm |
| Output bearings | 2, each 238 N axial and 950 N radial |
| Encoders | two on board, 16-bit |
| Sensing | phase current, temperature |
| Drive | integrated, STM32G4, 14 kHz current loop, 40 A peak phase current |
| Bus | FDCAN or classic CAN, power and data daisy-chained |
| Supply | 24 V, 2 to 3 W idle |
On the bus a drive answers on an even 11-bit id derived from its chip's serial number, and sends its state on the odd id next to it. It keeps its part, joint number, zero, direction and motor preset in its own memory.
The head
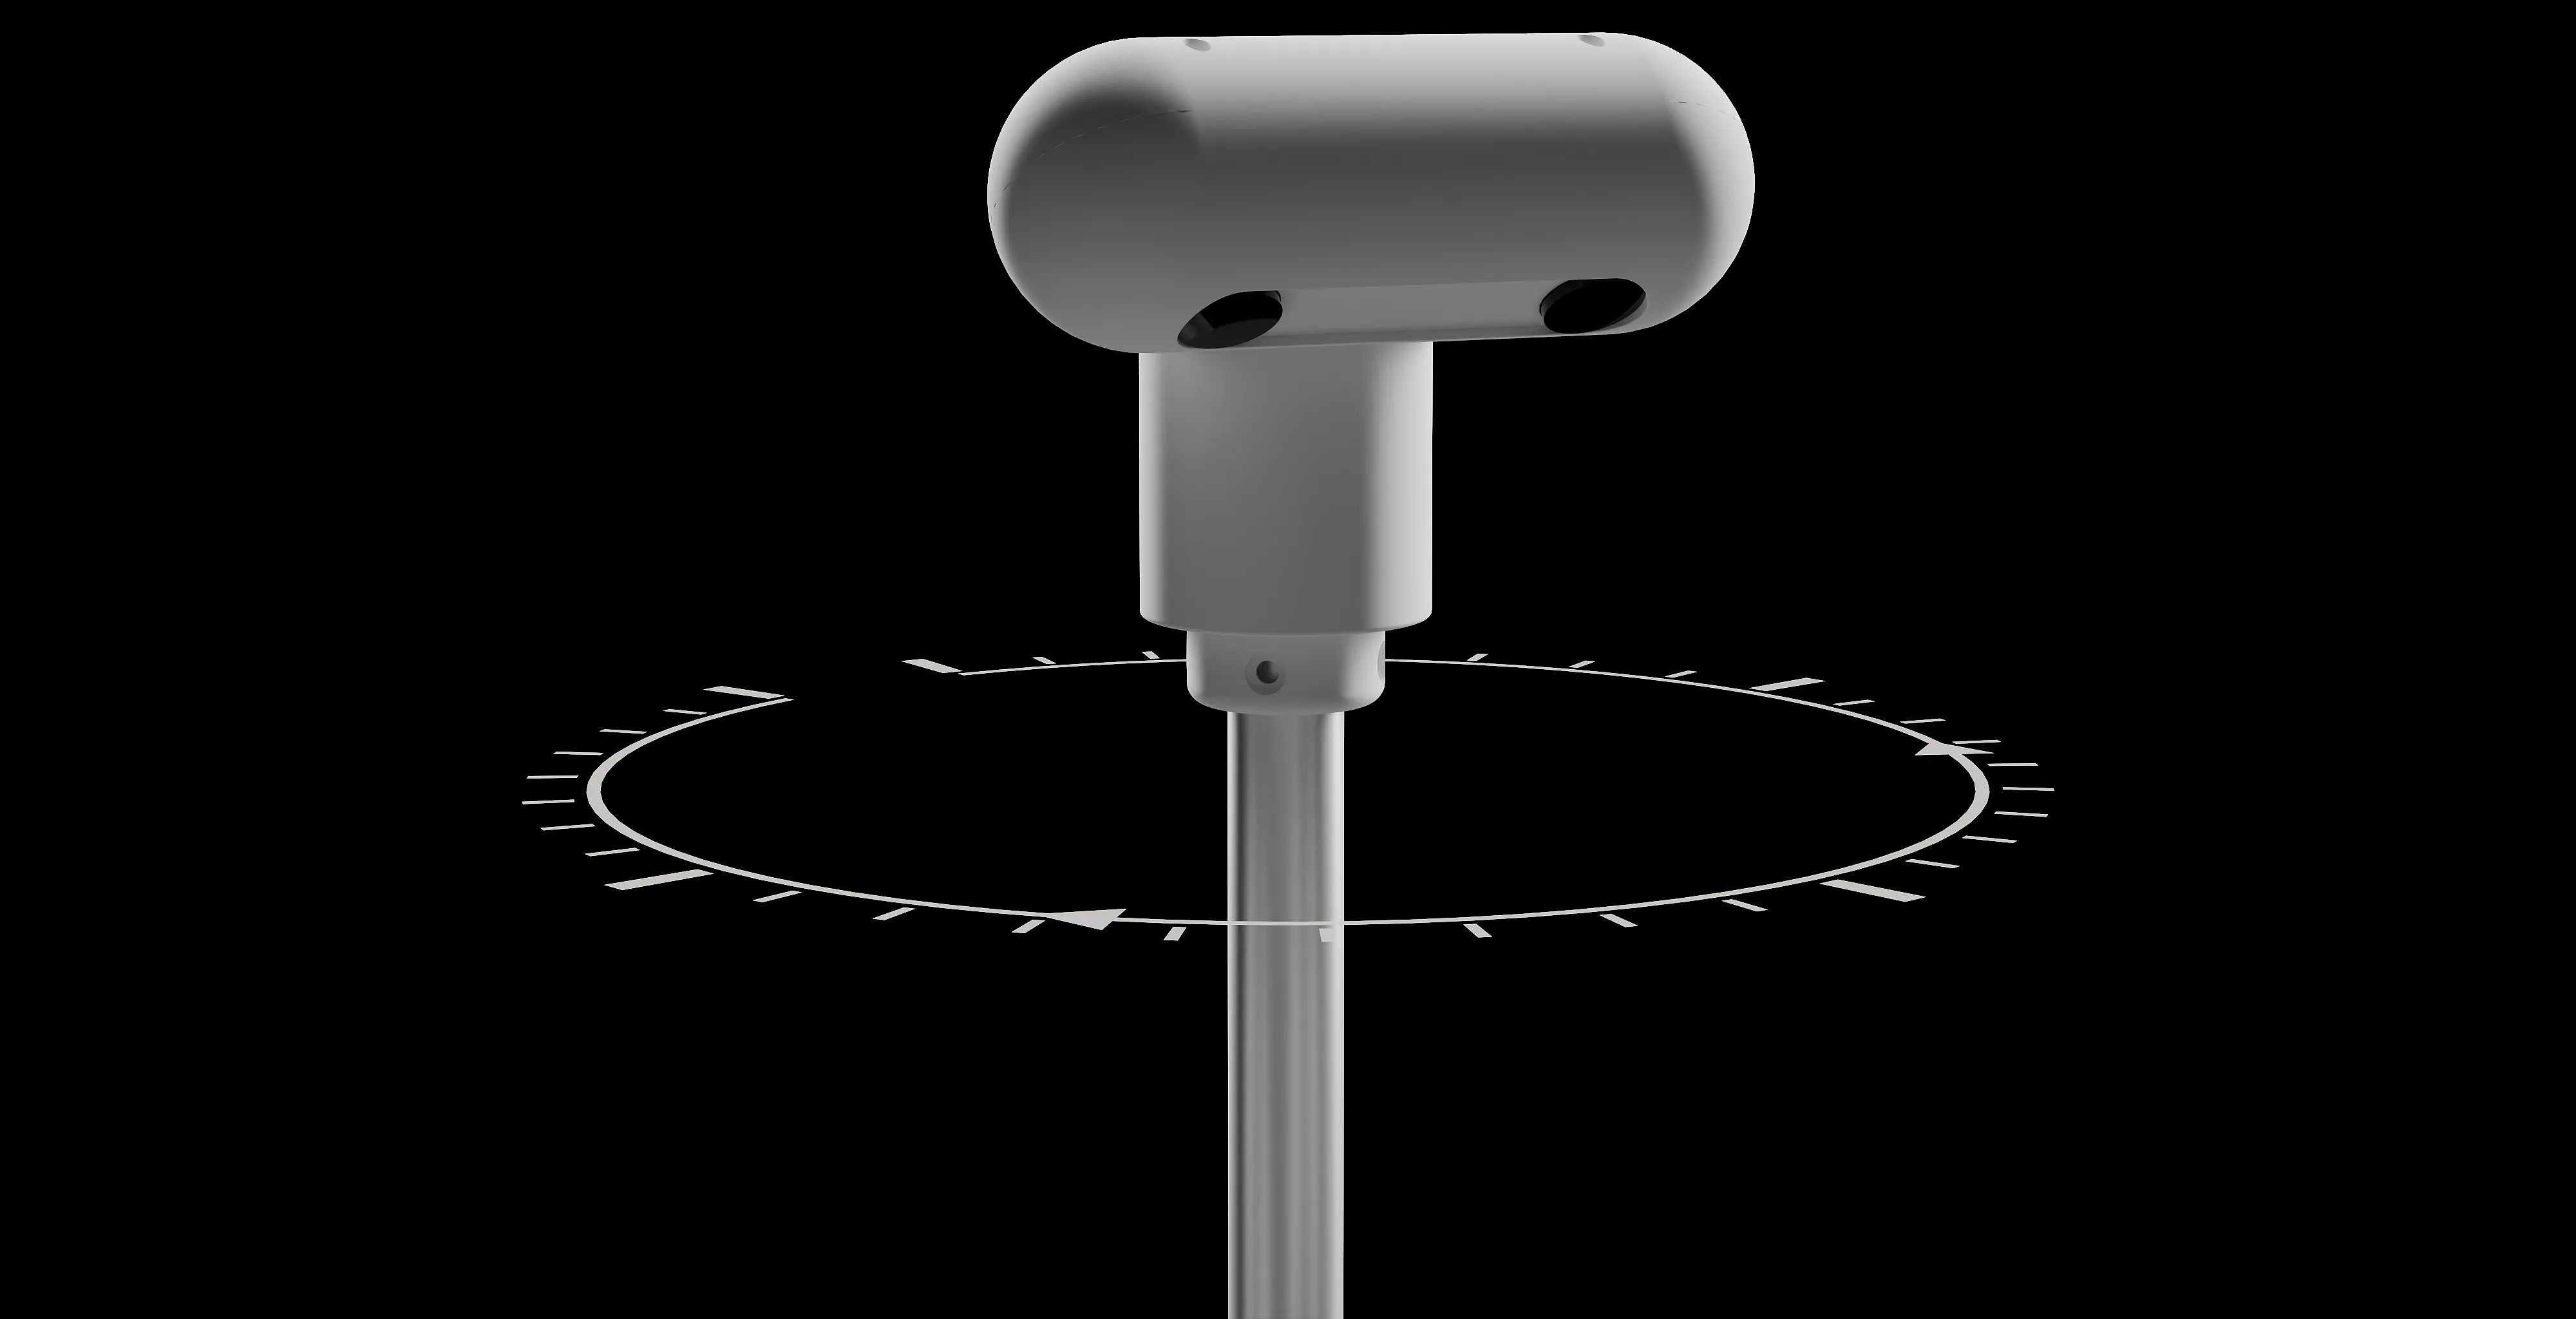
A turning stereo head: two wide cameras and a yaw drive (head, radians, positive to the robot's right, 0 straight ahead). It streams its two cameras at 56 frames per second each, in one of two modes:
| Mode | What each head camera sends |
|---|---|
| Full res, the default in the Robot Console, the VR app and the Python SDK | its whole picture, 2304 x 1296 |
| Foveated, one switch away | a 1152 x 648 context picture, plus a sharp 640 x 640 fovea (320 x 320 with eye tracking) that the robot cuts out where you look |
Both modes are coded on the robot by MAKIINA's own H.264 encoder. Either way, the detail you can point at is that of a 2304 x 1296 camera per eye, a combined 4608 x 1296 across both eyes, wider than a 4K frame. In full res the SDK's foveas are windows your PC cuts out of the full pictures. Each gripper adds a camera (224 x 224), streamed by the robot's second computer.
The robot
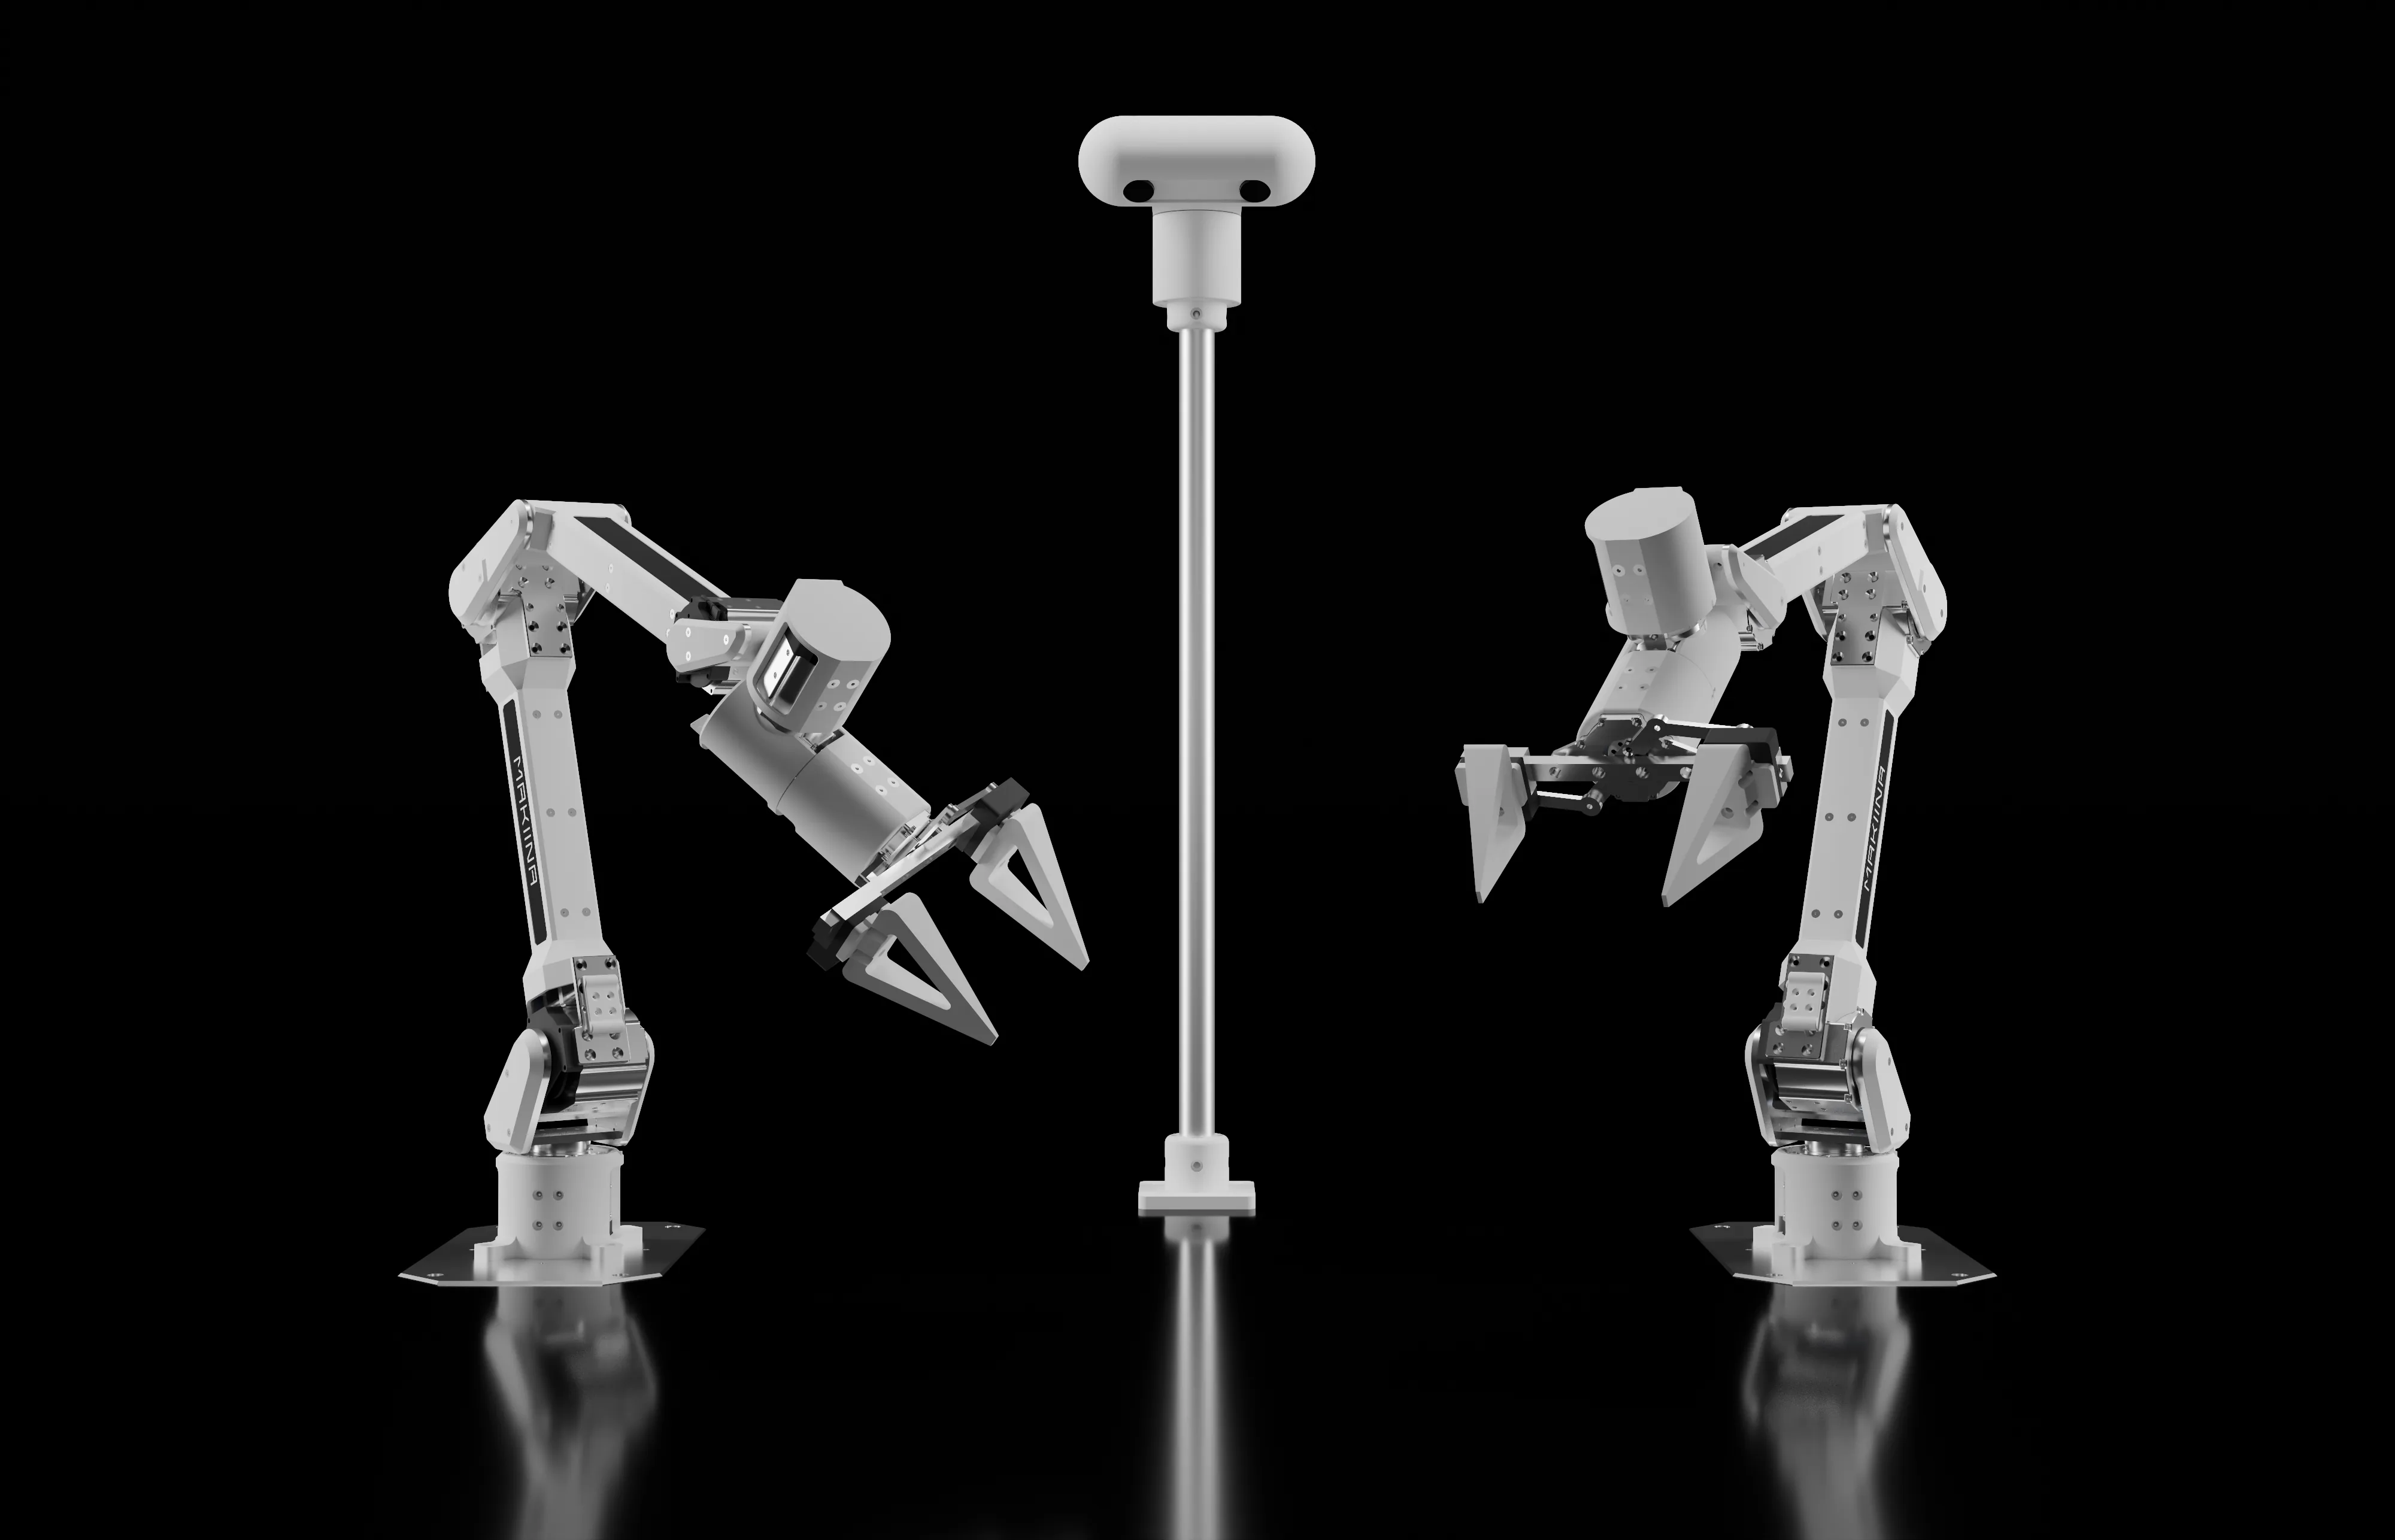
Two arms with grippers and the head, with two small computers, each on a network cable. The head computer drives both arms and the head, streams the head cameras and connects the robot to MAKIINA Cloud; the gripper computer streams the two gripper cameras. You drive the robot through your MAKIINA account from anywhere, and you look after it on its Robot admin page, http://<robot>.local:8726 with the name on its card, from a PC on its network. Software updates are signed release files that never change the computers' operating system, kernel or bootloader version.
USB CAN adapters
The SDK works with USB CAN adapters at 1 Mbit/s. An adapter must run candleLight firmware; the adapters that come with MAKIINA hardware do. On Windows each adapter needs its driver once on every PC (Give the adapter its driver on Windows), and on Linux your user needs permission to open it (a udev rule, see Install the SDK).
On the bench
- Keep a hand near the switch of the 24 V supply while you try something new.
- Set
safety.set_torque_fraction(0.4)andsafety.set_max_joint_velocity(1.0)before the first motion command. torque_off()lets the arm fall under its own weight. Hold it first.zerofolds the arm flat and closes the elbow fully. Keep your fingers out from between the upper arm and the forearm.